RoboParty Unveils RP1 Open-Source Humanoid at IROS
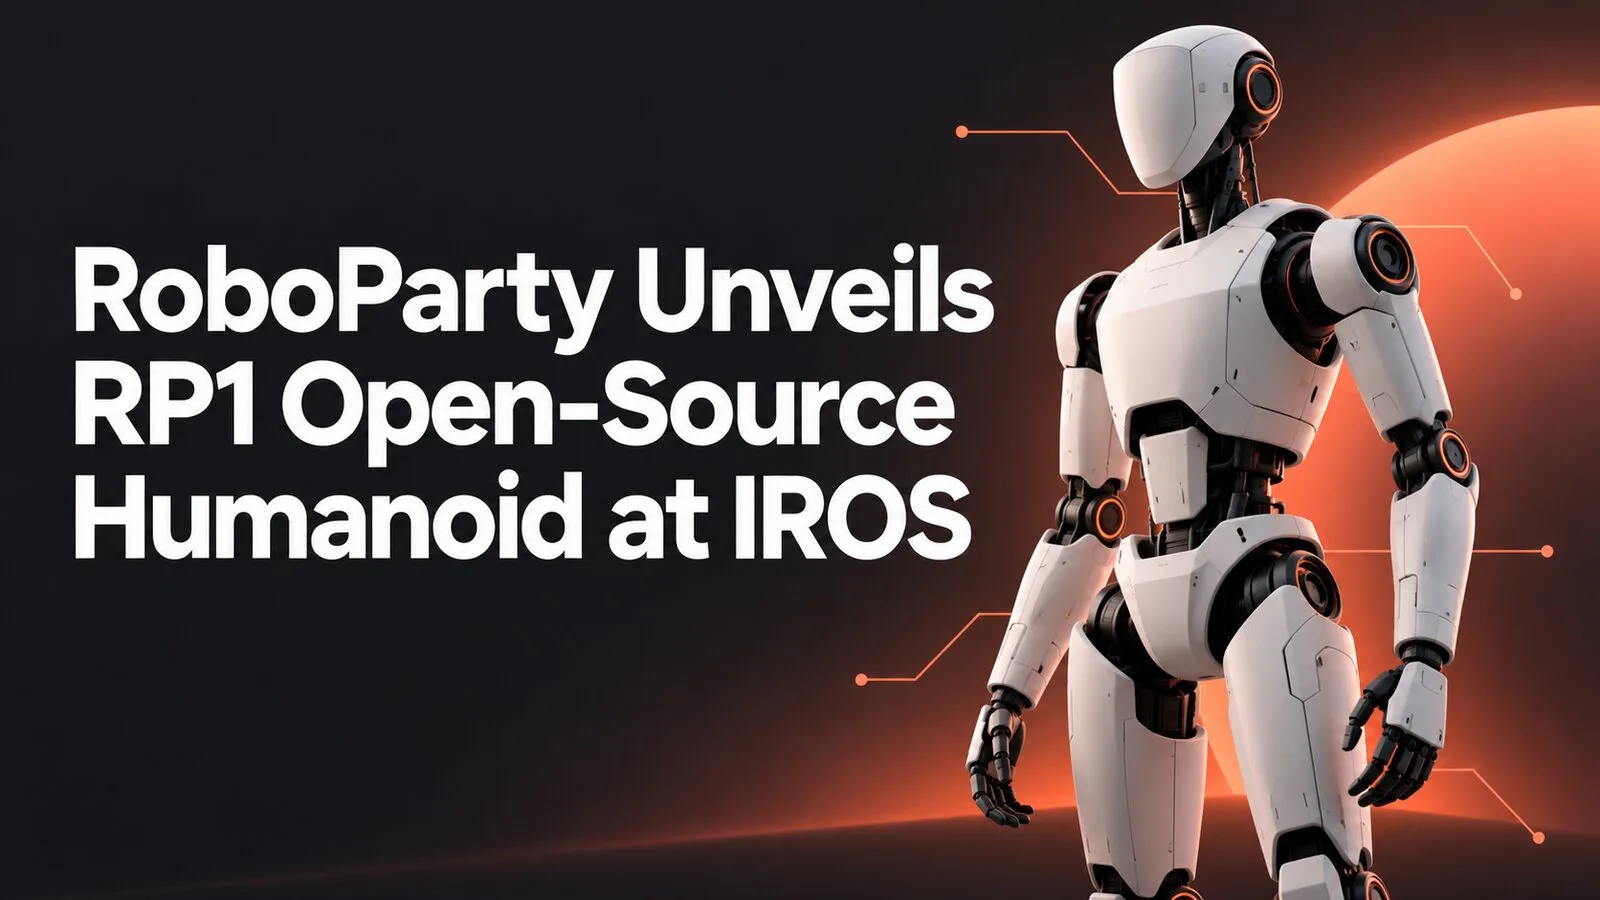
RoboParty unveils RP1, a bipedal humanoid platform that the Shanghai startup plans to open across hardware, motion control, simulation and AI training tools. The robot made its global debut at IROS 2026 in Pittsburgh on September 28, followed by a detailed launch announcement on October 3.
RP1 is aimed at researchers, educators and embodied-AI developers who need a modifiable system rather than a closed demonstration machine. The launch has three measurable elements:
- Peak joint torque is rated at 160 N·m.
- PartyOS links control and learning tools.
- Broader releases are promised for this quarter.
RoboParty Unveils RP1 at IROS 2026
RoboParty presented RP1, also called ROBOTO 01, at the IEEE/RSJ International Conference on Intelligent Robots and Systems. The company describes the machine as a research platform for dynamic locomotion, embodied-AI training, validation, deployment and data collection.
The IROS booth included a hands-on balance demonstration in which visitors pushed the robot while it attempted to recover. RoboParty says RP1 adjusted its posture under those disturbances, but the demonstration is not an independent benchmark of stability, payload, endurance or fall resistance.
The launch is more consequential for its proposed development model than for a single staged capability. Humanoid teams often combine proprietary actuators, closed motion controllers and limited software interfaces, making it difficult for outside researchers to reproduce results or change the full control stack.
RoboParty wants RP1 to provide a common body, actuator layer and software environment that developers can inspect and extend. That could reduce duplicated integration work, although it will depend on the completeness of the released designs, documentation and interfaces.
RP1 Links Romomo Hardware to PartyOS
RP1 uses RoboParty's in-house Romomo actuator modules and a real-time motion-control system. The company specifies peak joint torque of up to 160 N·m, a manufacturer figure that describes maximum output rather than sustained performance across every joint or operating condition.
PartyOS is intended to connect data generation, motion retargeting, imitation learning, unsupervised reinforcement learning and higher-level interaction. Its public roadmap points to tools for locomotion, whole-body manipulation, vision-language-action systems and agentic humanoid behavior.
One component is UFO, an unsupervised reinforcement-learning framework for humanoid control. RoboParty says UFO can discover movement skills without predefined trajectories, including transitions between skills, disturbance recovery and fall recovery. The public repository gives researchers code to inspect, but RP1-specific performance remains a vendor claim until others reproduce it.
The stack also references Human-Humanoid Tools for motion retargeting, MimicLite for imitation learning and INTACT-JEPA for whole-body interaction research. This modular structure matters because teams can test one learning method without rebuilding every driver and deployment component from scratch.
Related Research
What RoboParty Has Already Opened
RoboParty's open-source record predates RP1. Its earlier ROBOTO ORIGIN project publishes mechanical, electronics, training and deployment work, and the repository has attracted about 2,500 GitHub stars. That existing code base gives the company more evidence than a launch-day promise alone.
The public PartyOS repository is licensed under GPLv3 and links several active subprojects. Its roadmap also labels some components as forthcoming, including data-generation infrastructure, showing that the proposed stack is not yet fully delivered in one finished release.
RoboParty's GitHub organization lists an RP1 repository described as an open platform covering hardware, an SDK, PartyOS and locomotion control. The listing establishes a public project boundary, but repository presence does not by itself confirm that complete production-ready files, bills of materials and reproducible training recipes are available.
Licensing will matter at each layer. PartyOS uses GPLv3, while linked subprojects can carry their own terms. Research groups and commercial builders will need to review the licenses, dependencies and hardware documentation before deciding whether RP1 can support redistribution or proprietary applications.
October Roadmap Will Test the Open-Source Claim
RoboParty says it will publish more details of the RP1 open-source roadmap during October. It also plans broader software and hardware releases and a mass-production program later in the fourth quarter, but has not disclosed pricing, shipment volumes or a firm customer-delivery date.
The key test is whether developers receive enough information to reproduce the robot's demonstrated behavior. Useful releases would include mechanical drawings, actuator specifications, low-level interfaces, calibration procedures, simulation models, training configurations and documented paths from a learned policy to real hardware.
External evidence will be equally important. Independent laboratories need to measure balance recovery, thermal limits, actuator durability, power consumption and repeated task performance. Open code can accelerate that work, but it does not remove the engineering difficulty or cost of operating a full-size biped.
RP1 enters a market where humanoid companies increasingly promise general bodies for embodied AI. RoboParty's differentiator is its attempt to open multiple layers at once. The October roadmap will show whether that ambition becomes a reproducible research platform or remains ahead of the materials developers can actually use.